Loading 3D model… large boards can take a moment.
The LineFollower Robot is an autonomous robot designed to follow a predefined path marked by a black or white line.
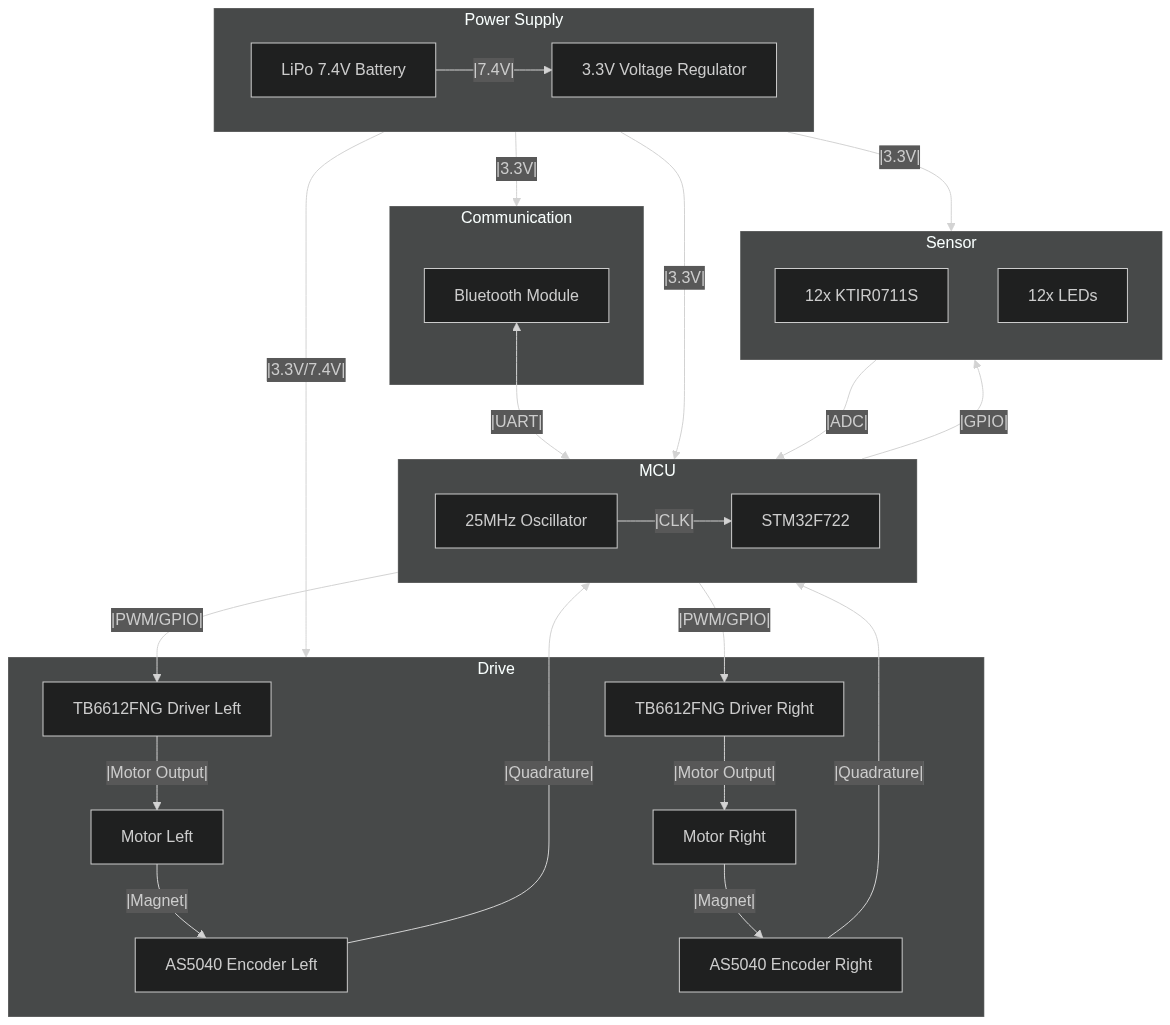
This project serves a quite advanced solution including hardware project, embedded software and PC QT application.
A short video demo is available on YouTube.
Example - one of the first - linefollower run:
Electronic circuit diagrams are available in the Hardware/release/schematic folder.
Gerbers files are available in the Hardware/release/gerbers folder.
Main board:
Sensor board:
Encoder board:
The core functionality is implemented through an event-driven state machine. The primary signal is the LF_SIG_ADC_DATA_UPDATED, which is raised whenever new ADC data is available. Currently every 5ms, however increasing this frequency can lead to better control results.
The activity diagram presents simplified main robot algorithm in RUN state:
Short brief about implemented software components:
Implemented bootloader allows for over the air firmware updates without the need of programmer. This is particularly useful for making quick updates "on the road." The bootloader uses the implemented SCP (Serial Communication Protocol) to receive firmware updates over Bluetooth.
There are 2 methods to enter the Bootloader:
FLASH memory layout:
The QT Application provides a graphical interface to control, configure, and monitor the robot. The main sections of the interface and their functionalities are as follows:
No comments yet. Be the first to ask about this board.